On this page
Arduino SimpleFOCShield v4.1


This is an open-source low-cost Brushless DC (BLDC) motor and Stepper driver board intended for low and mid-power FOC applications, up to 5A continuous and 8A peak. The board is fully compatible with the Arduino UNO and all the boards with the standard Arduino headers. The SimpleFOCShield, in combination with the SimpleFOClibrary provides user-friendly way to control BLDC motors both in hardware and software.
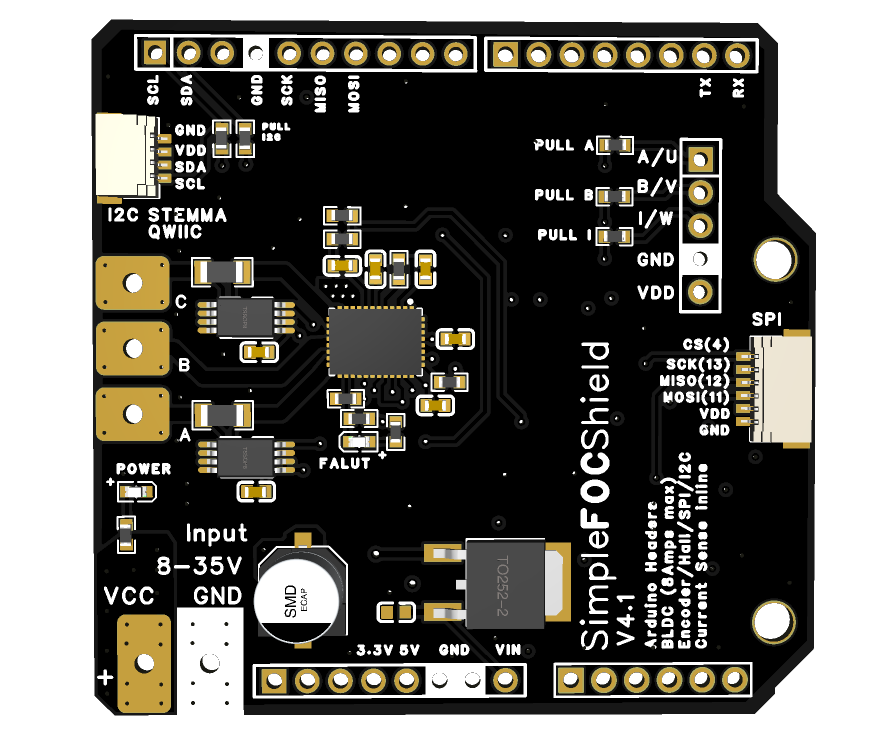
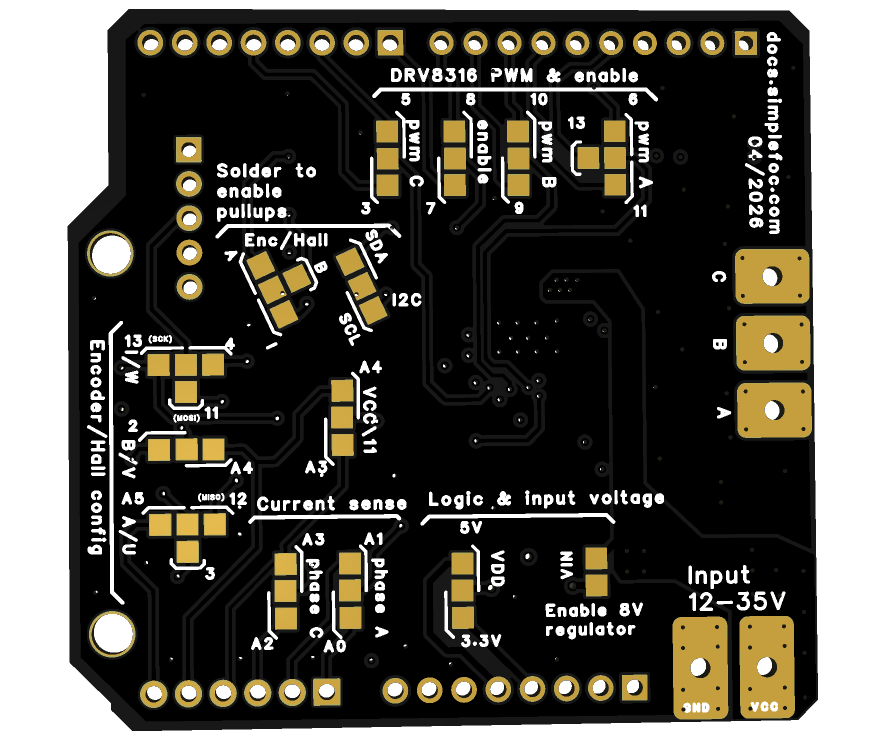
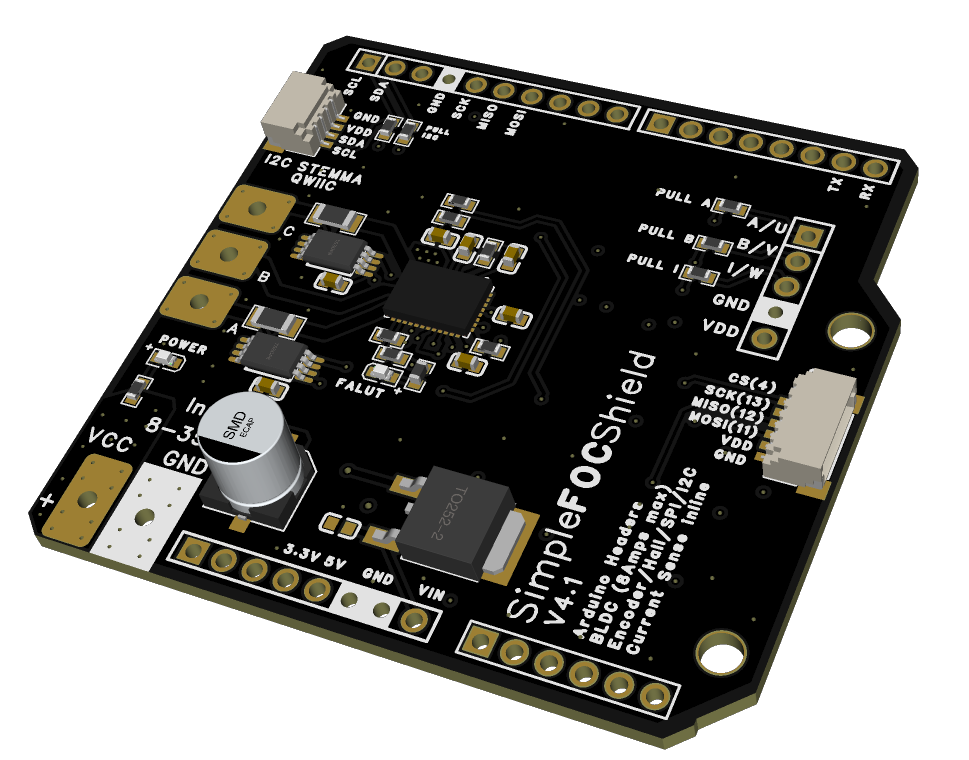
Get started with your board Fabricate the board
Features
- Plug & play: In combination with Arduino SimpleFOClibrary - github
- Low-cost: Price of 15-30€ - Check the pricing
- DRV8316 driver: 3-5A continuous, 8A peak
- Protections: undervoltage, overcurrent, overtemperature, with a fault LED
- In-line current sensing: bidirectional, ±6.6A (3.3V) or ±10A (5V)
- INA240A2 current sense amplifiers (gain 50, 5mΩ shunts)
- Power supply voltage sensing: optional voltage divider (1/11)
- Max input voltage: 35V
- Integrated 8V regulator: powers the MCU board, enable/disable by soldering pads
- Stackable: running 2 motors in the same time
- Encoder/Hall sensors interface: Integrated 3.3kΩ pullups (configurable)
- I2C interface: Integrated 4.7kΩ pullups (configurable)
- QWIIC/STEMMA QT connector: 4-pin JST connector for I2C sensors and modules
- SPI connector: 6-pin JST connector for SPI magnetic sensors
- Configurable pinout: Hardware configuration - soldering connections
- Arduino headers: Arduino UNO, Arduino MEGA, STM32 Nucleo boards…
- Open Source:
- Fully designed in EasyEDA Pro: EasyEDA project 🎉
- Fully available fabrication files - how to make it yourself
New features of the version v4.x
- Transition from the DRV8313 to the DRV8316 driver, with a much higher current capacity: 8A peak instead of 3A
- Transition from the ACS712 Hall sensors back to TI’s INA240 current amplifiers, for more precise current sensing
- Power supply voltage sensing
- SPI and QWIIC/STEMMA QT JST connectors
- Designed completely in EasyEDA Pro, a free online PCB design tool - Official EasyEDA project
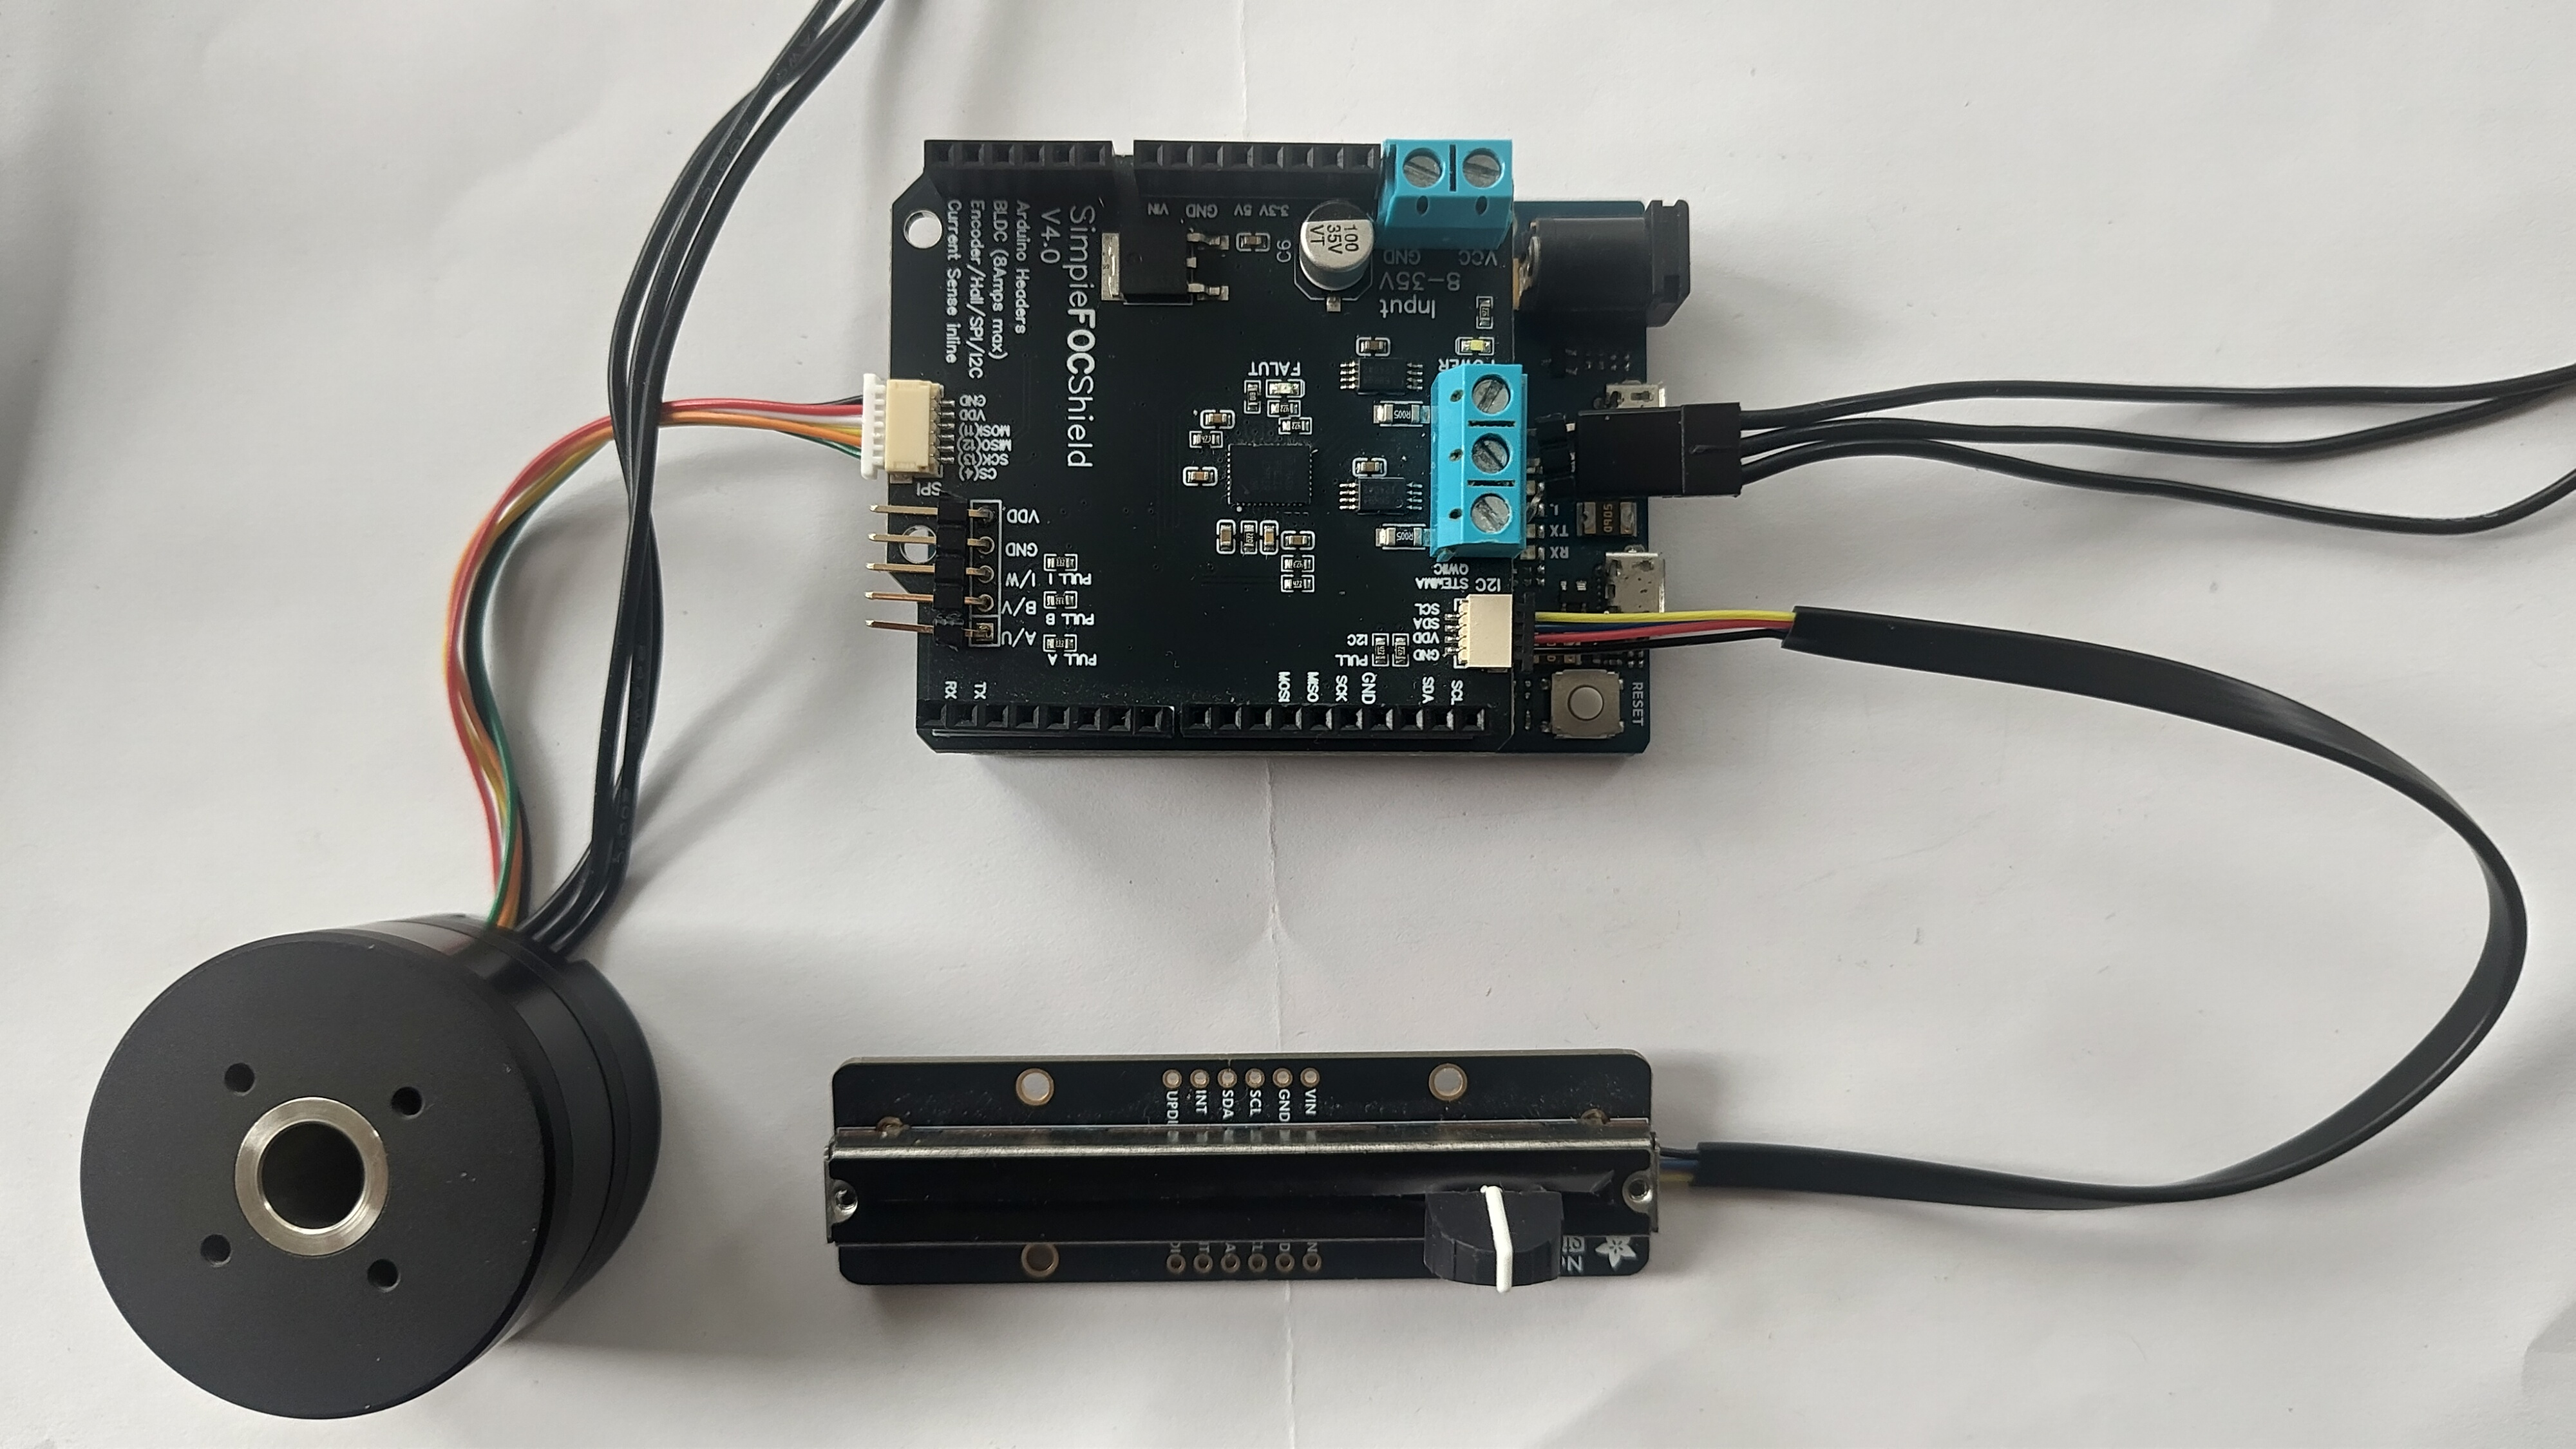
Upgrading from v3
The pin options of the solder pads are the same as on v3, so your pinout carries over. Check the v4 soldering pads for what’s new, and update the current sensing code, as the amplifiers have changed.
YouTube demonstration video
This video shows an older version of the board.
Board version comparison
| Feature | SimpleFOCShield v1.x | SimpleFOCShield v2.x | SimpleFOCShield v3.x | SimpleFOCShield v4.x |
|---|---|---|---|---|
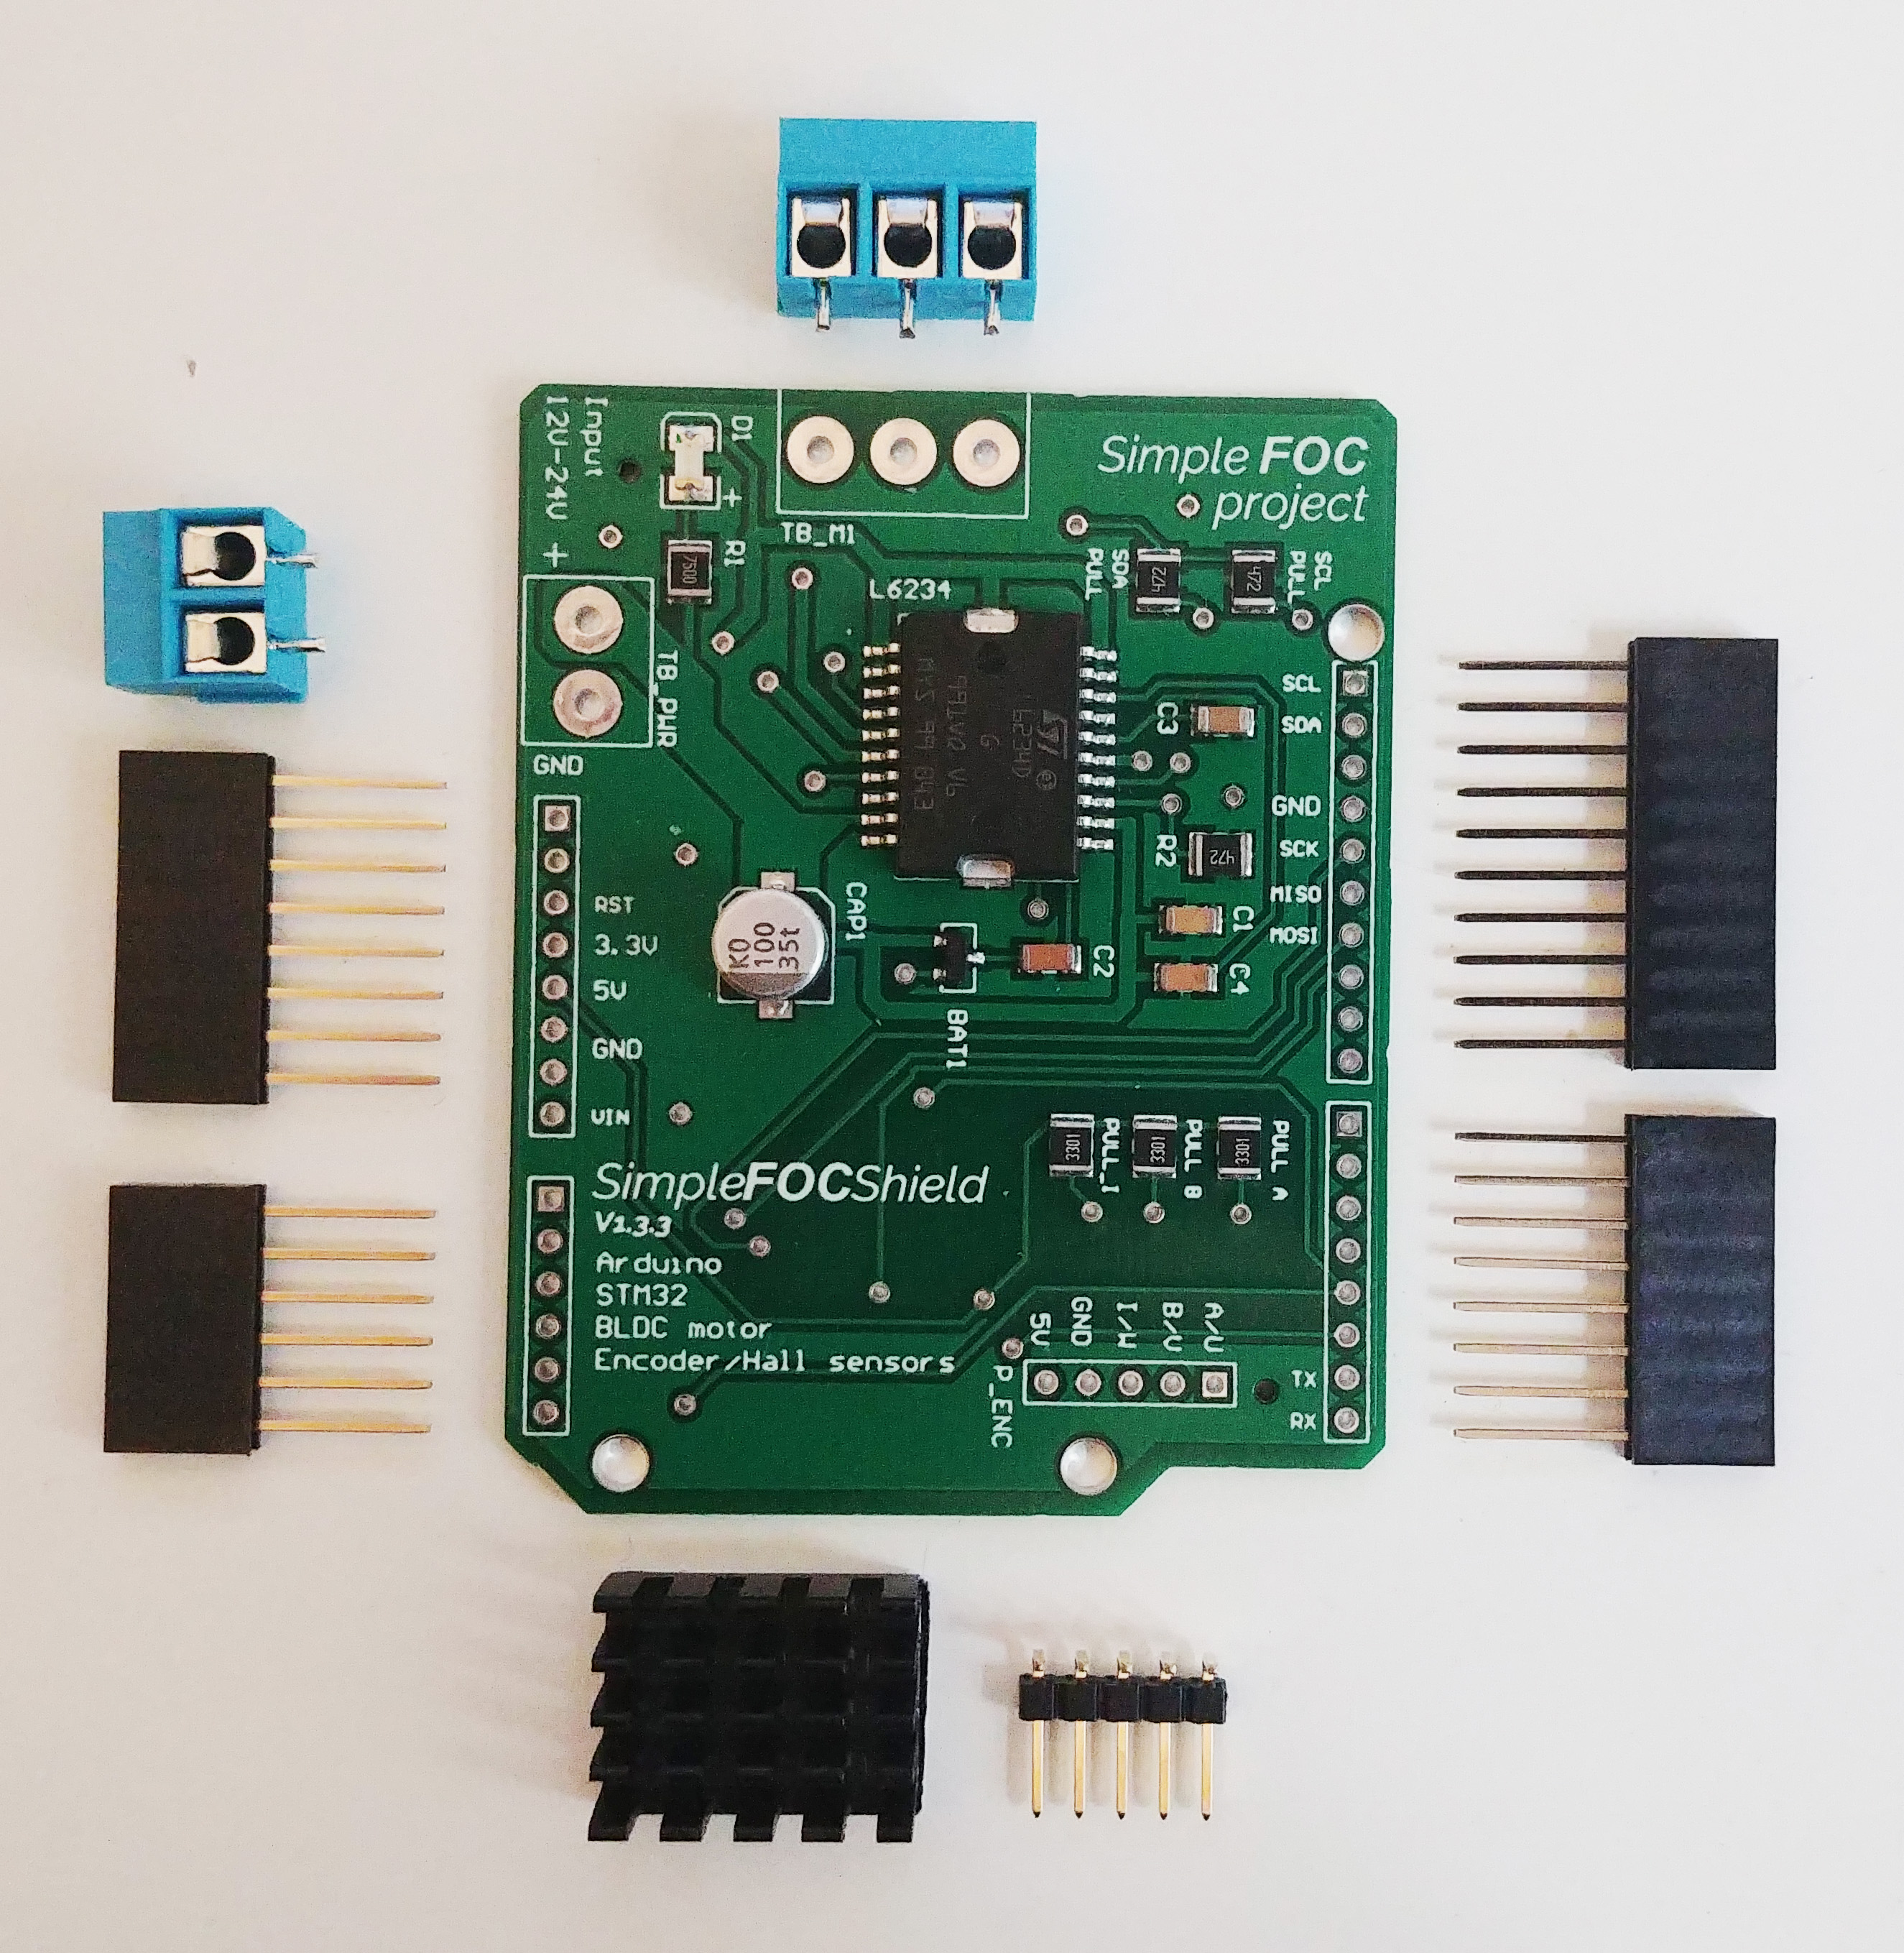 | 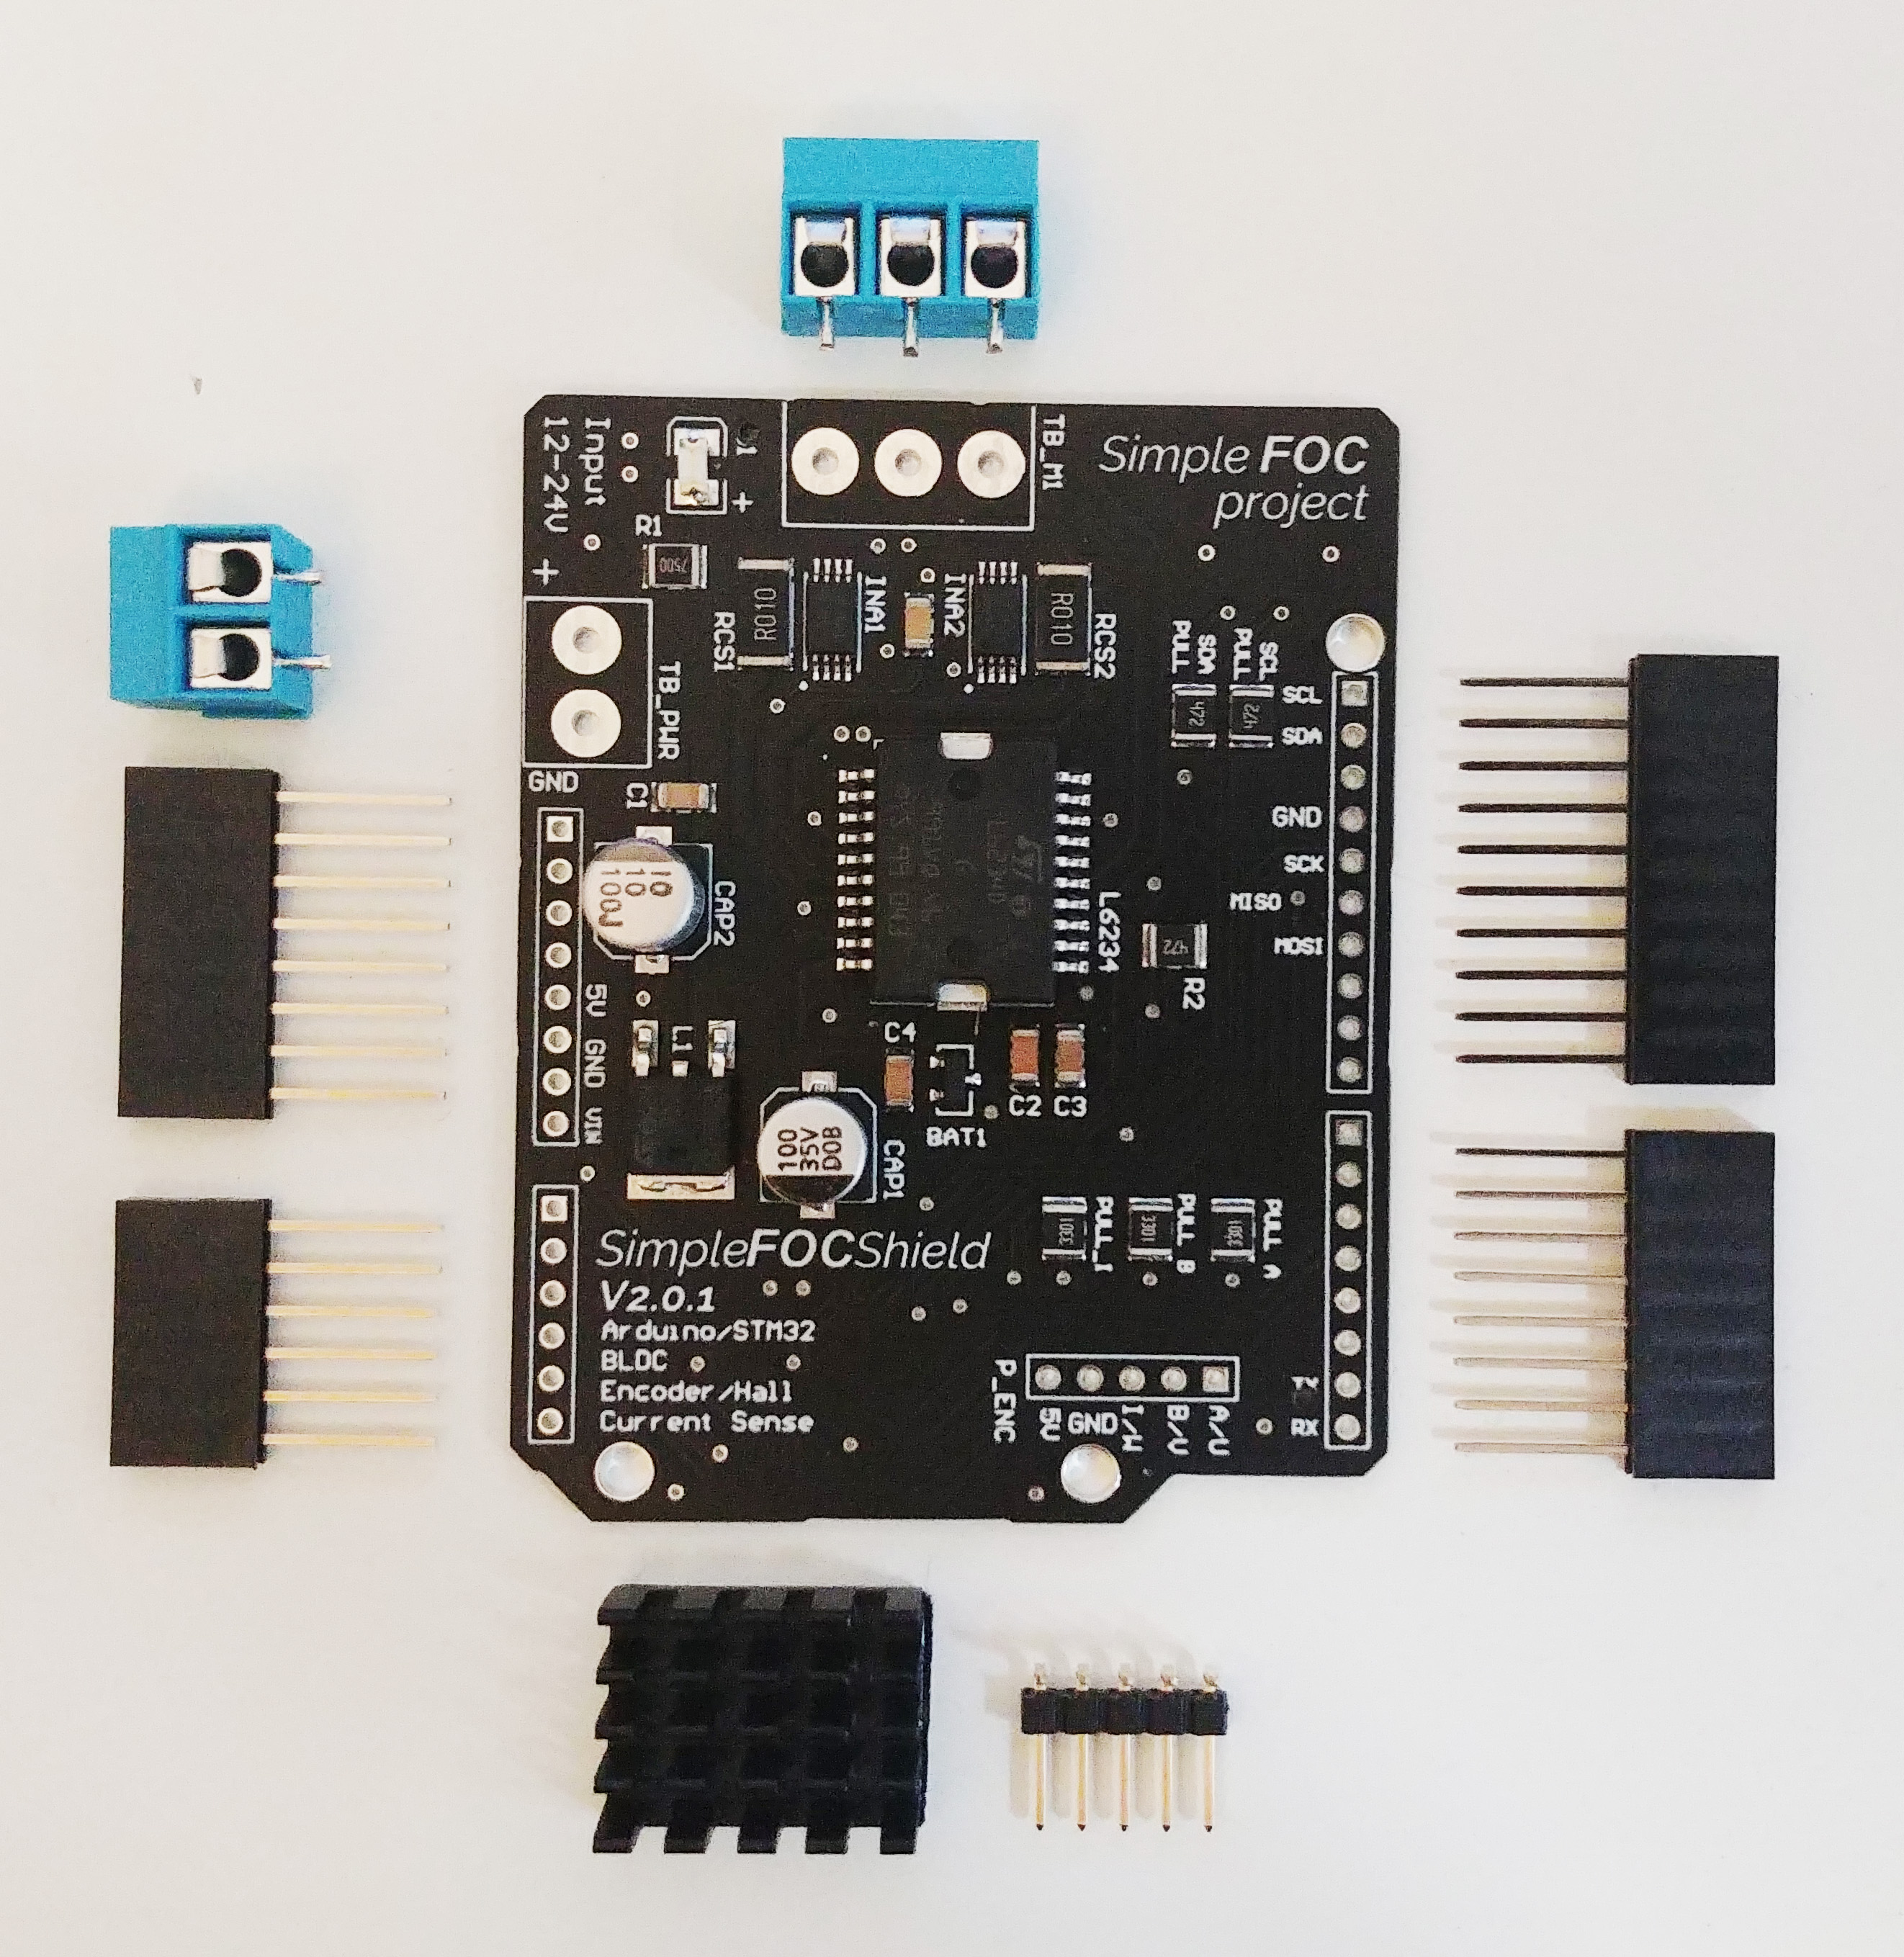 | 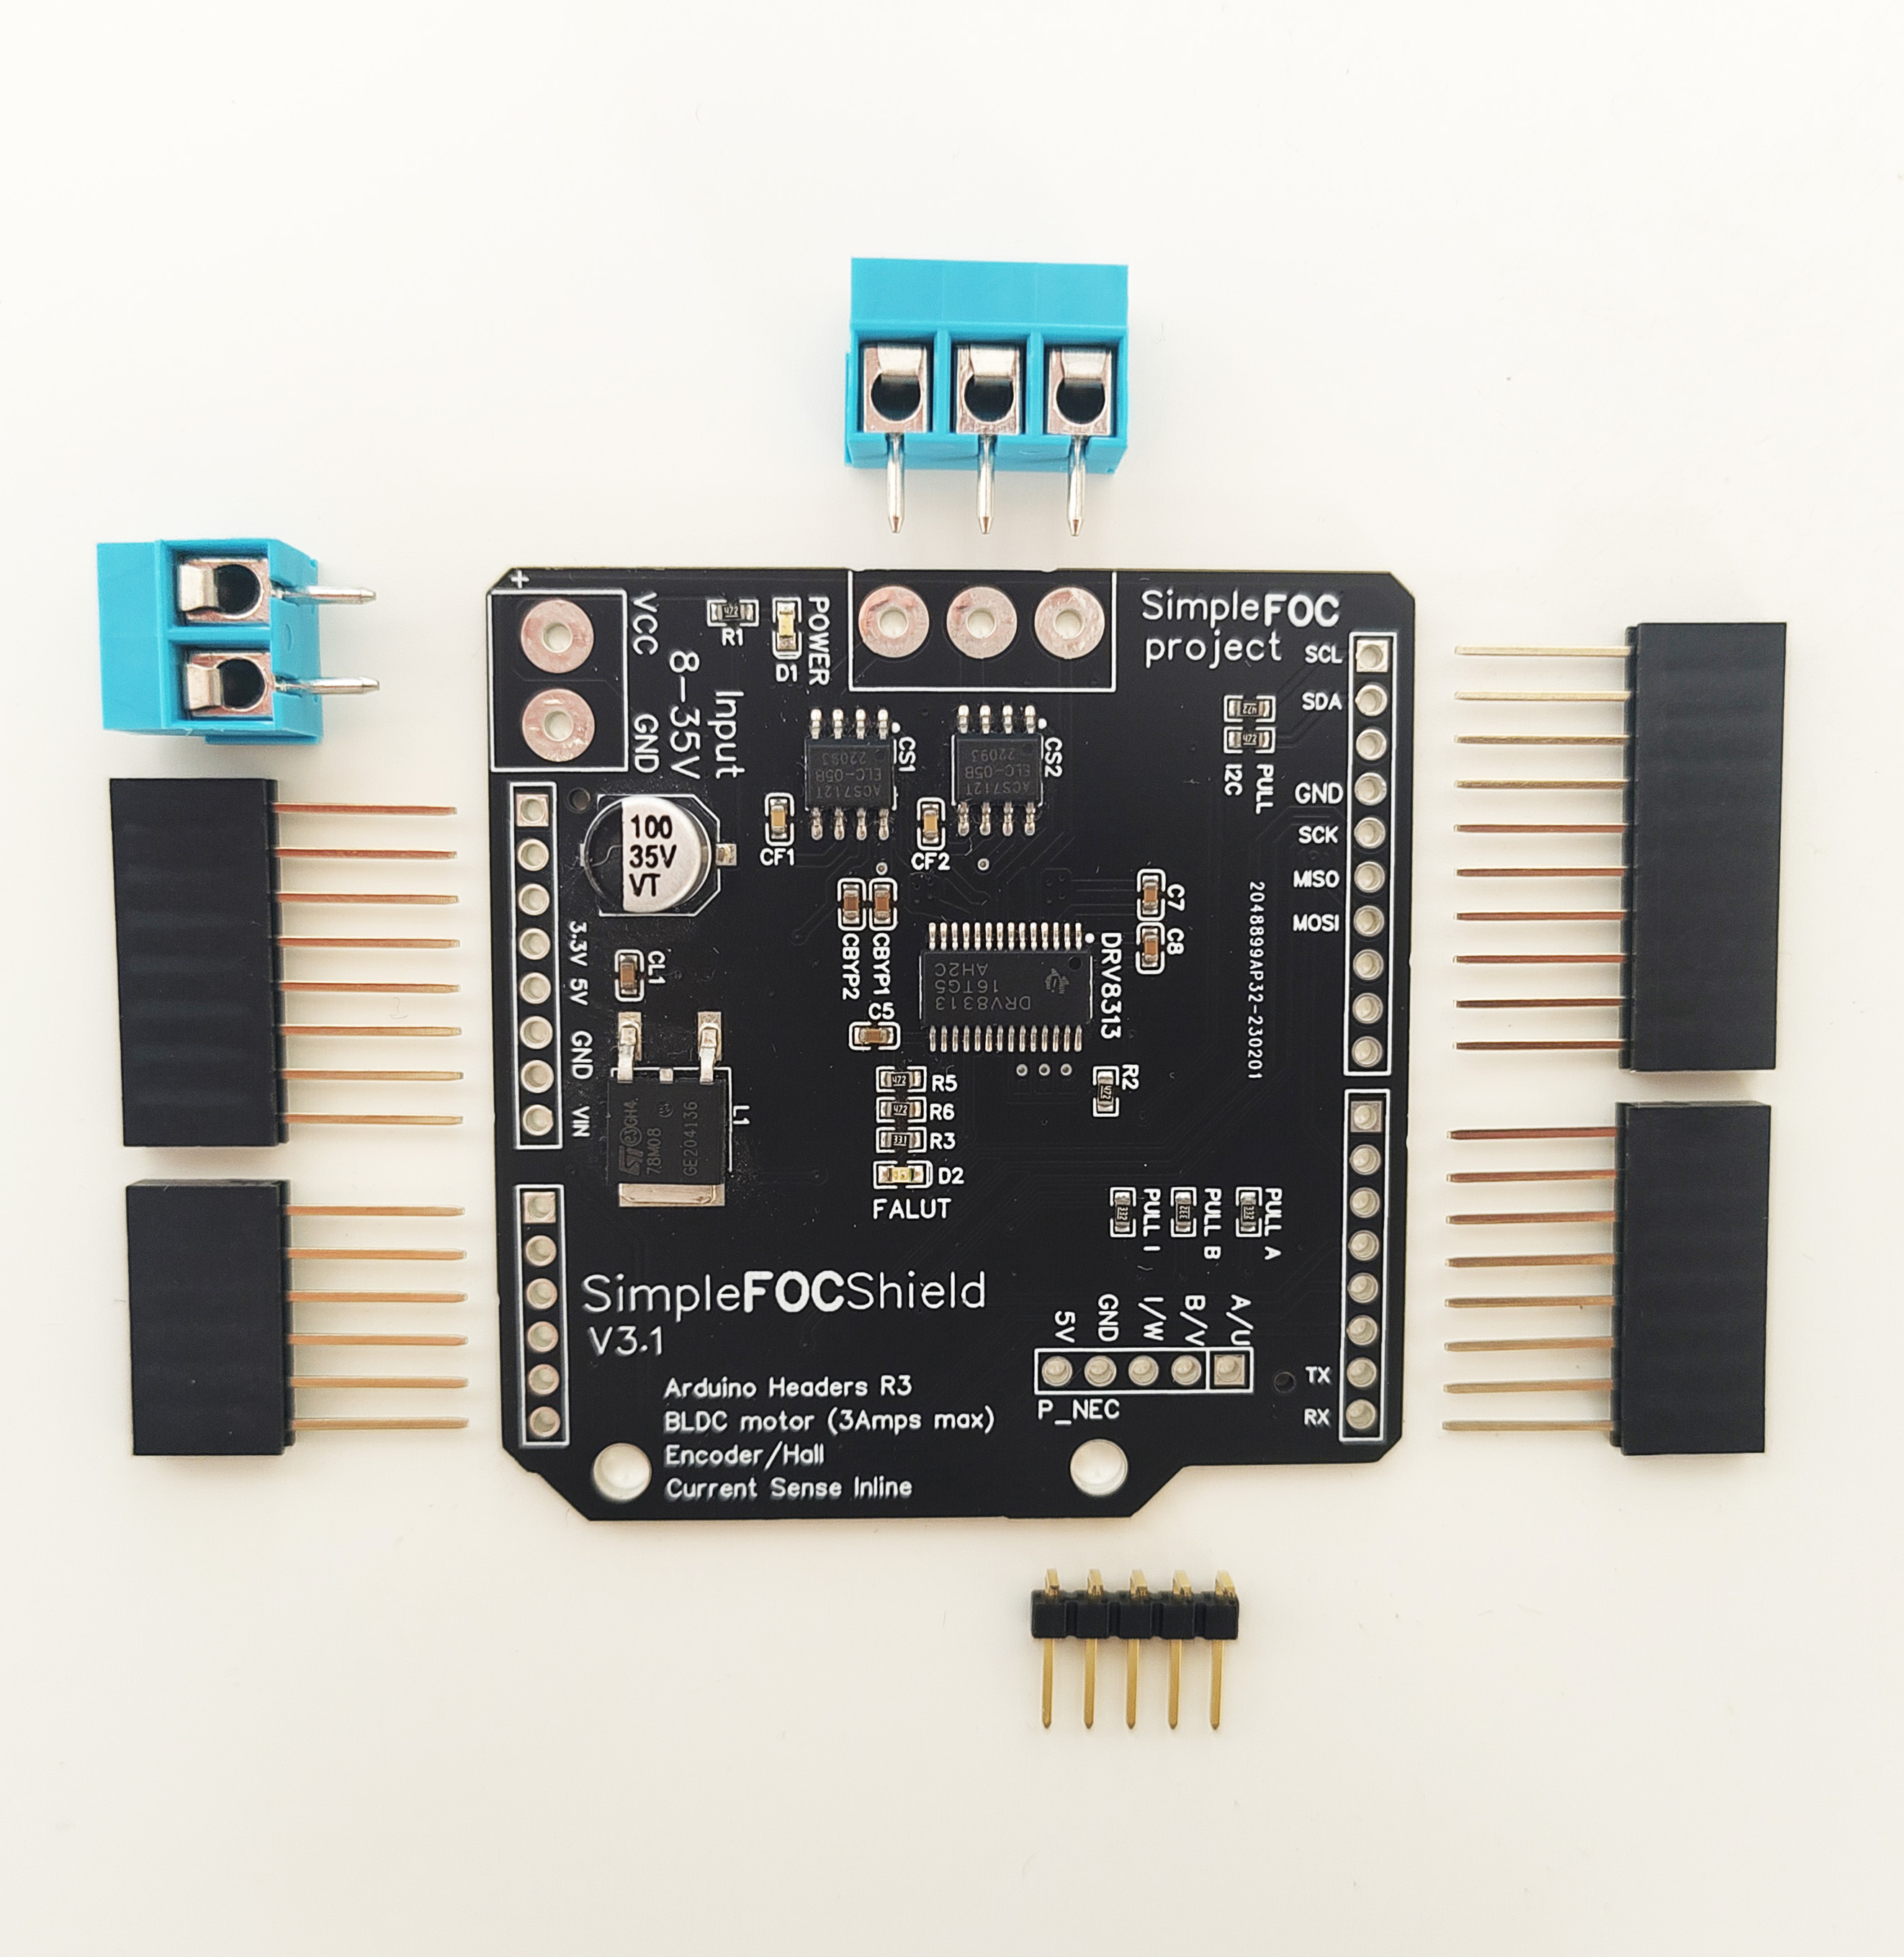 | 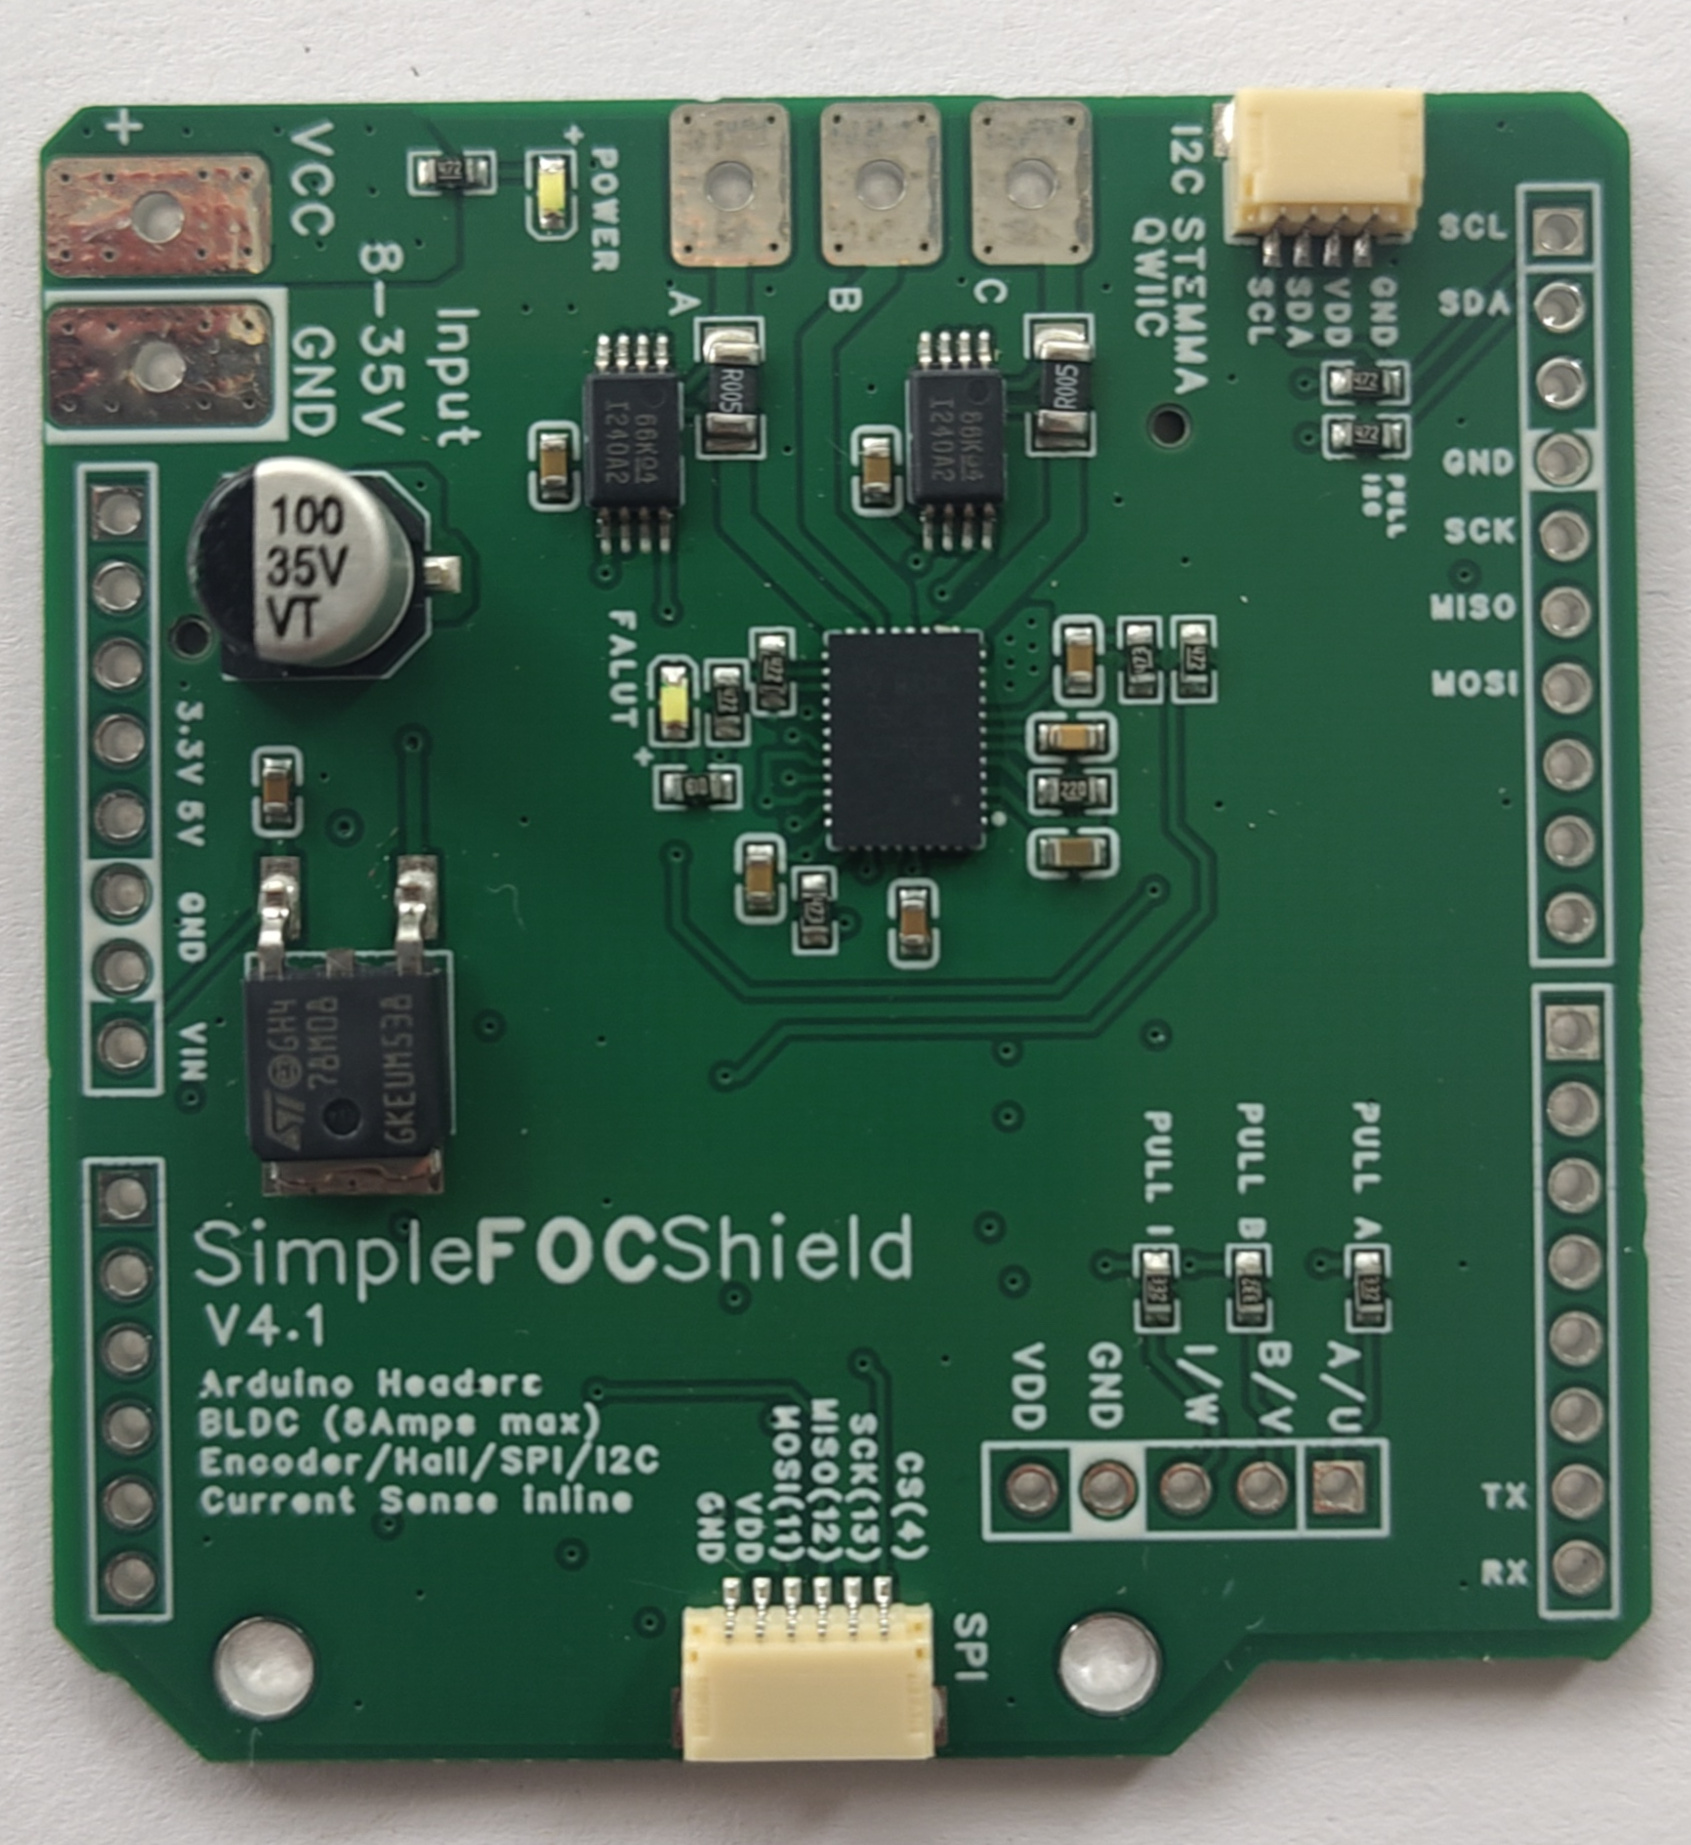 | |
| PWM Driver | L6234 | L6234 | DRV8313 | DRV8316 |
| Current Sense | ❌ | INA240 | ACS712 | INA240 |
| Current measurement range | ❌ | (configurable) ±3.3/5Amps | ±5Amps | ±6.6A (3.3V) / ±10A (5V) |
| Voltage sensing | ❌ | ❌ | ❌ | ✔️ |
| Onboard LDO | ❌ | LM7808 | LM7808 | L78M08 |
| Max current | 2Amps (5Amp peak) | 2Amps (5Amp peak) | 2Amps (3Amp peak) | 3-5Amps (8Amp peak) |
| Max voltage | 24V | 35V | 35V | 35V |
| Protections | Overtemperature | Overtemperature | Overtemperature, Overcurrent | Undervoltage, Overcurrent, Overtemperature |
| Stackable | ✔️ | ✔️ | ✔️ | ✔️ |
| I2C pullups | ✔️ | ✔️ | ✔️ | ✔️ |
| Encoder pullups | ✔️ | ✔️ | ✔️ | ✔️ |
| SPI / QWIIC connectors | ❌ | ❌ | ❌ | ✔️ |
| Footprint | 68mm x 53 mm | 68mm x 53 mm | 56mm x 53mm | 56mm x 53mm |
| Design tool | Altium Designer 2019 | Altium Designer 2019 | EasyEDA | EasyEDA Pro |
Connection schematic
An electrical connection example of a BLDC motor with an encoder as position sensor.
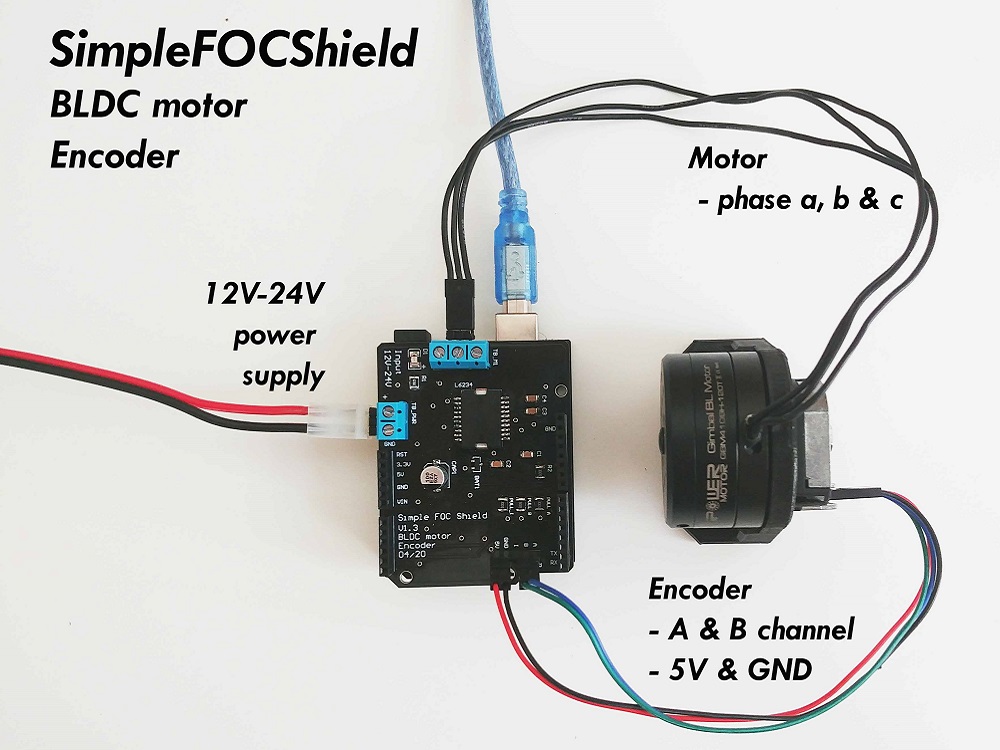
For more information about how to connect you hardware to your shield, check the full connection example.
Project example : Reaction wheel inverted pendulum
This is a project of designing and controlling the reaction wheel inverted pendulum based entirely on Arduino SimpleFOClibrary and SimpleFOCShield
This is a very fun project in many ways, and it is intended:
- Students in search for a good testing platform for their advanced algorithms
- Everyone with a bit of free time and a motivation to create something cool :D
For full documentation of necessary components, design choices and the code please visit the project docs.
Project example : Steer by wire - bidirectional haptic control examples
This video demonstrates SimpleFOCShield support for stacking with Arudino UNO and STM32 Nucleo-64 board. As well as support for different sensors magnetic and encoders with relatively large precision span.
The control algorithms implemented in this project are :
- Steer by wire (force feedback): two motors with virtually coupled positions
- Interactive gauge (haptic velocity control): two motors with virtually coupled position and velocity
For full documentation of the projects setup and the code please visit the project docs.
Getting started
You already have your own SimpleFOCShield?
Here is a simple guide how to start preparing your setup
How to get hold of the SimpleFOCShield
- Fabricate the board yourself: Please visit the board fabrication to find out how to manufacture the board yourself!
- Order the finished and tested board: Check out our shop. The v4.1 will also be available from Makerfabs soon.