On this page
SimpleFOCMini v2.3


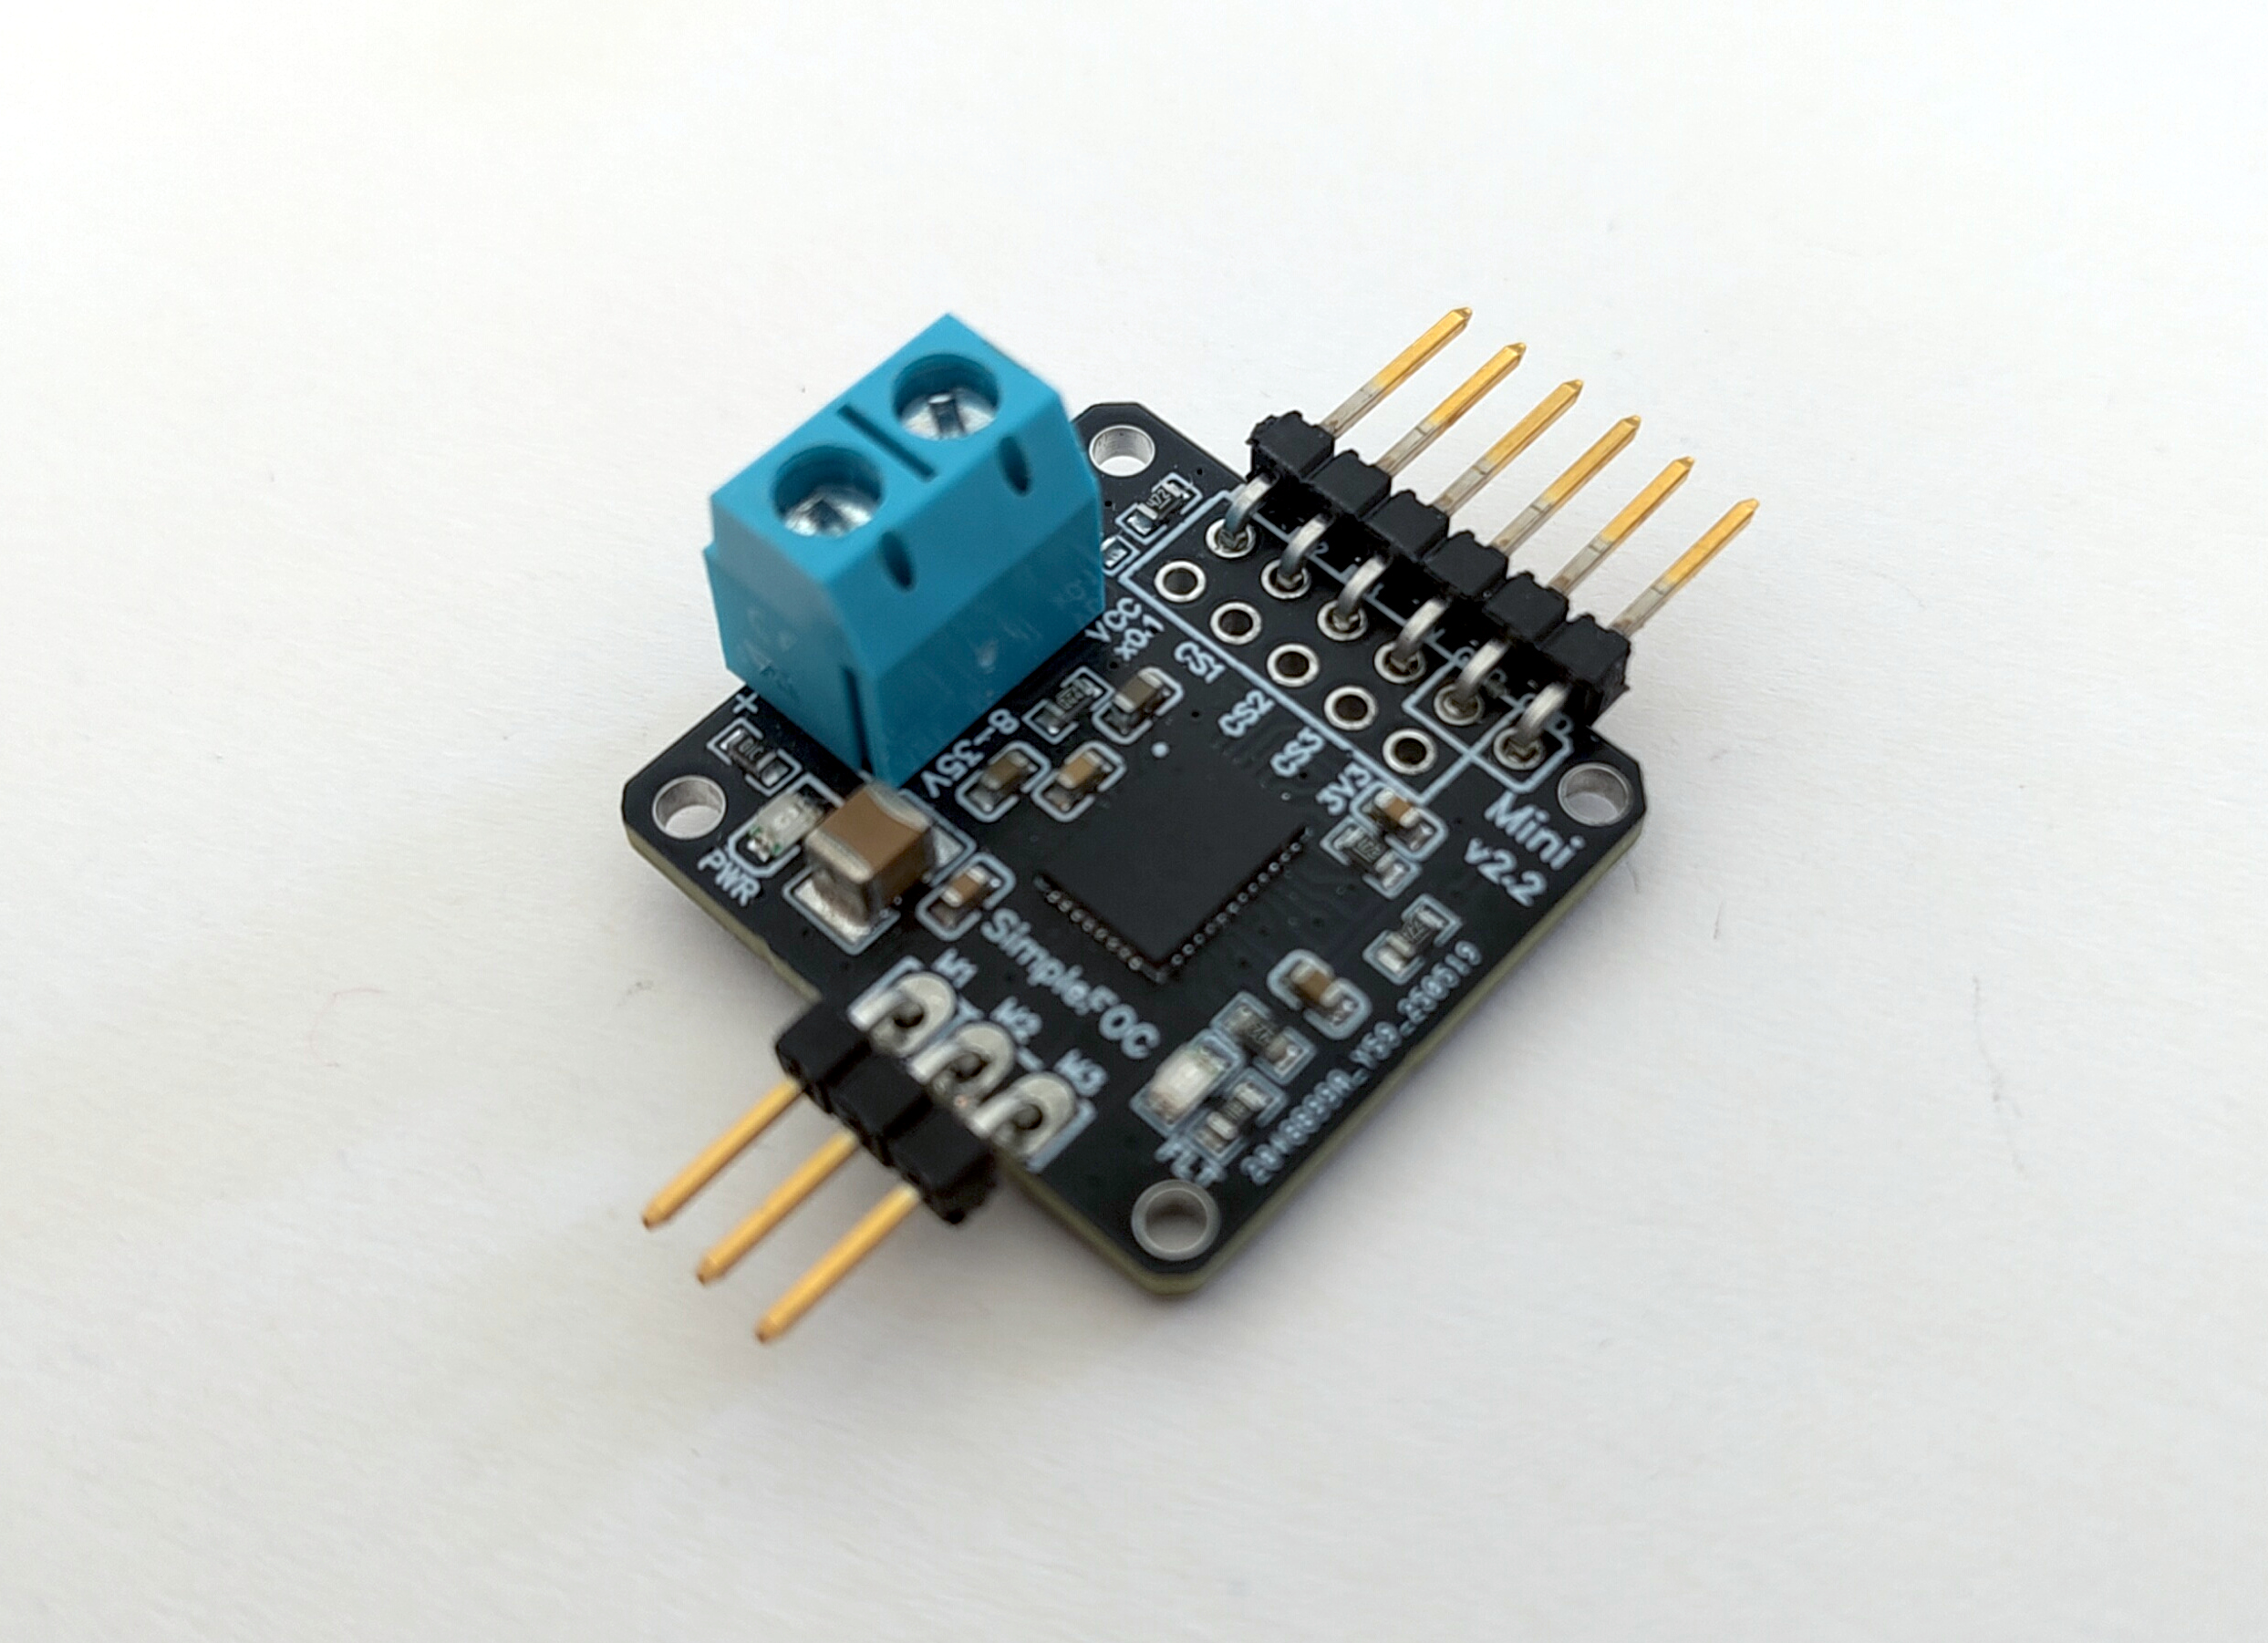
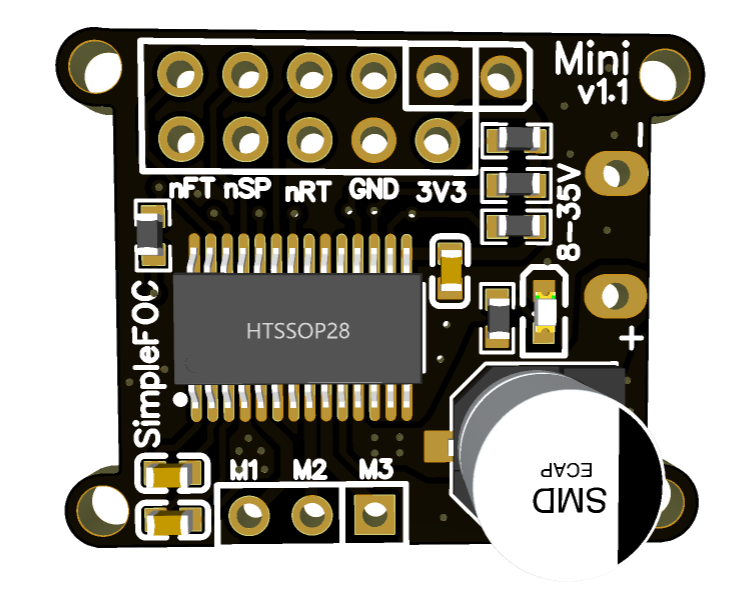
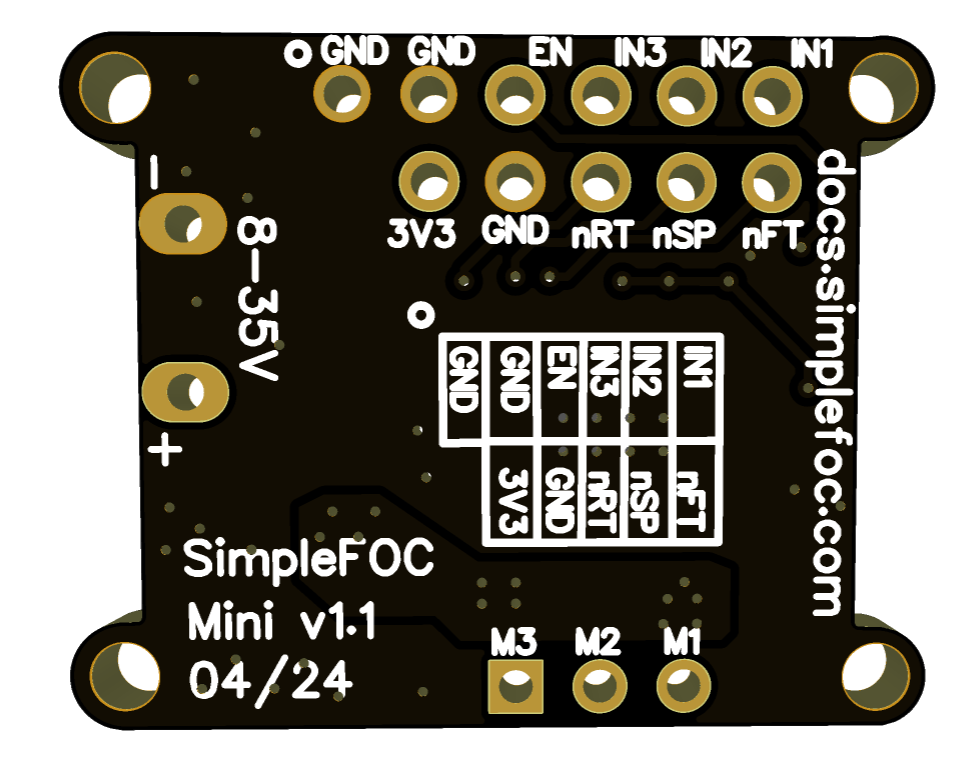
SimpleFOCMini is a compact BLDC driver for use with the SimpleFOClibrary. Version 2 replaces the DRV8313 with a DRV8316 and adds three-phase low-side current sensing and supply-voltage sensing. Its PWM and enable pinout remains compatible with Mini v1.1, so existing control code can be reused.
Get started with your mini board
Version features comparison
| Feature | Mini v1.1 | Mini v2.3 |
|---|---|---|
| Image | 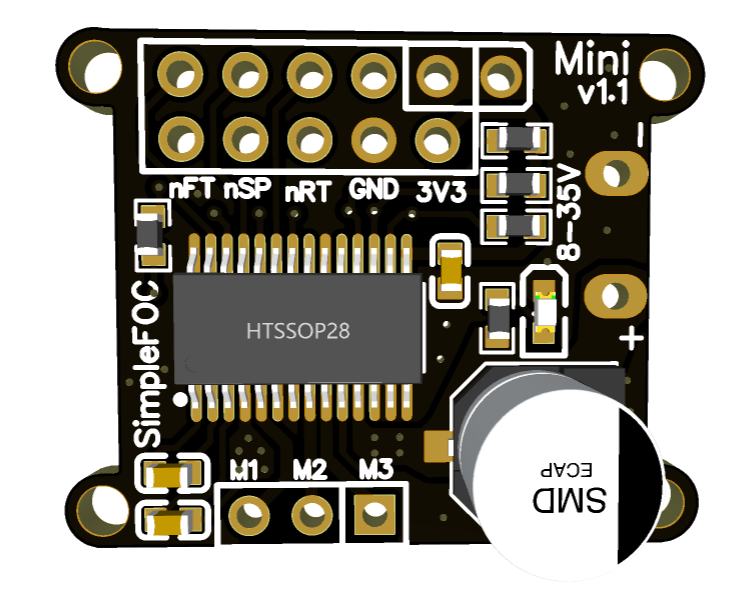 | |
| Motor driver | DRV8313 | DRV8316 |
| Power supply | 8-35V | 5-35V |
| Maximum current | 2.5A per phase | 8A |
| Current sensing | Not integrated | Three-phase low-side (150mV/A) |
| Supply-voltage sensing | Not integrated | Integrated (0.101V/V scale) |
| 3.3V regulator output | Up to 10mA | Up to 20mA |
| Board size | 20 x 26mm | 24 x 25mm |
| PWM and enable pinout | Original layout | Compatible with v1.1 |
The v2.3 board is a complete redesign, but retains the v1.1 PWM and enable pinout and is compatible with code written for Mini v1.
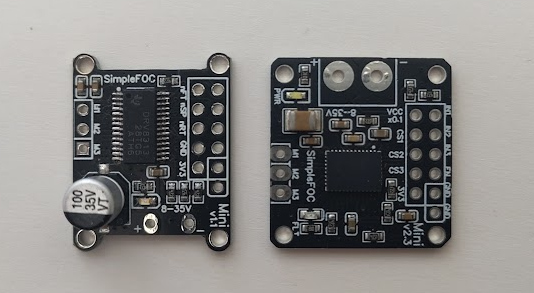
Features of SimpleFOCMini v2.3
- Plug & play: In combination with Arduino SimpleFOClibrary
- DRV8316 based - datasheet
- Power supply: 5-35V
- Maximum current: 8A
- 3-PWM mode
- Sensing:
- 3x Low-side current sensing (150mV/A)
- Power supply voltage sensing (Scale 0.101V/V)
- Onboard 3.3V LDO: Up to 20mA output
- Small size: 24x25 mm
- Fully open-source:
- Low-cost:
- JLCPCB production cost ~5€
- Available from Makerfabs
Low-side current-sensing compatibility
Mini v2 uses low-side current sensing. Not all supported microcontrollers can use this sensing method; check the [microcontroller support guide](microcontrollers) before relying on current control. Observe the board's voltage and current ratings when selecting a motor and power supply.
Release log
| Release | Date | Description |
|---|---|---|
| v2.3 | 2025-07 | Smaller layout and supply-voltage sensing. |
| v2.0 | 2025-01 | Redesigned around the DRV8316 with three-phase low-side current sensing. |
| v1.1 | 2024-04 | A quick iteration with a few changes: 1. Aligned motor output header with the input header so that it can be stacked in the protoboard 2. Input header updated to be easier to use with arduino UNO, nucleos, but also with qtpy… - Changed the order of the IN1,IN2,IN3 and EN: - Added an additional GND pin |
| v1.0 | 2022-04 | Initial release |
Connection schematic
An electrical connection example of a BLDC motor with an encoder as position sensor.
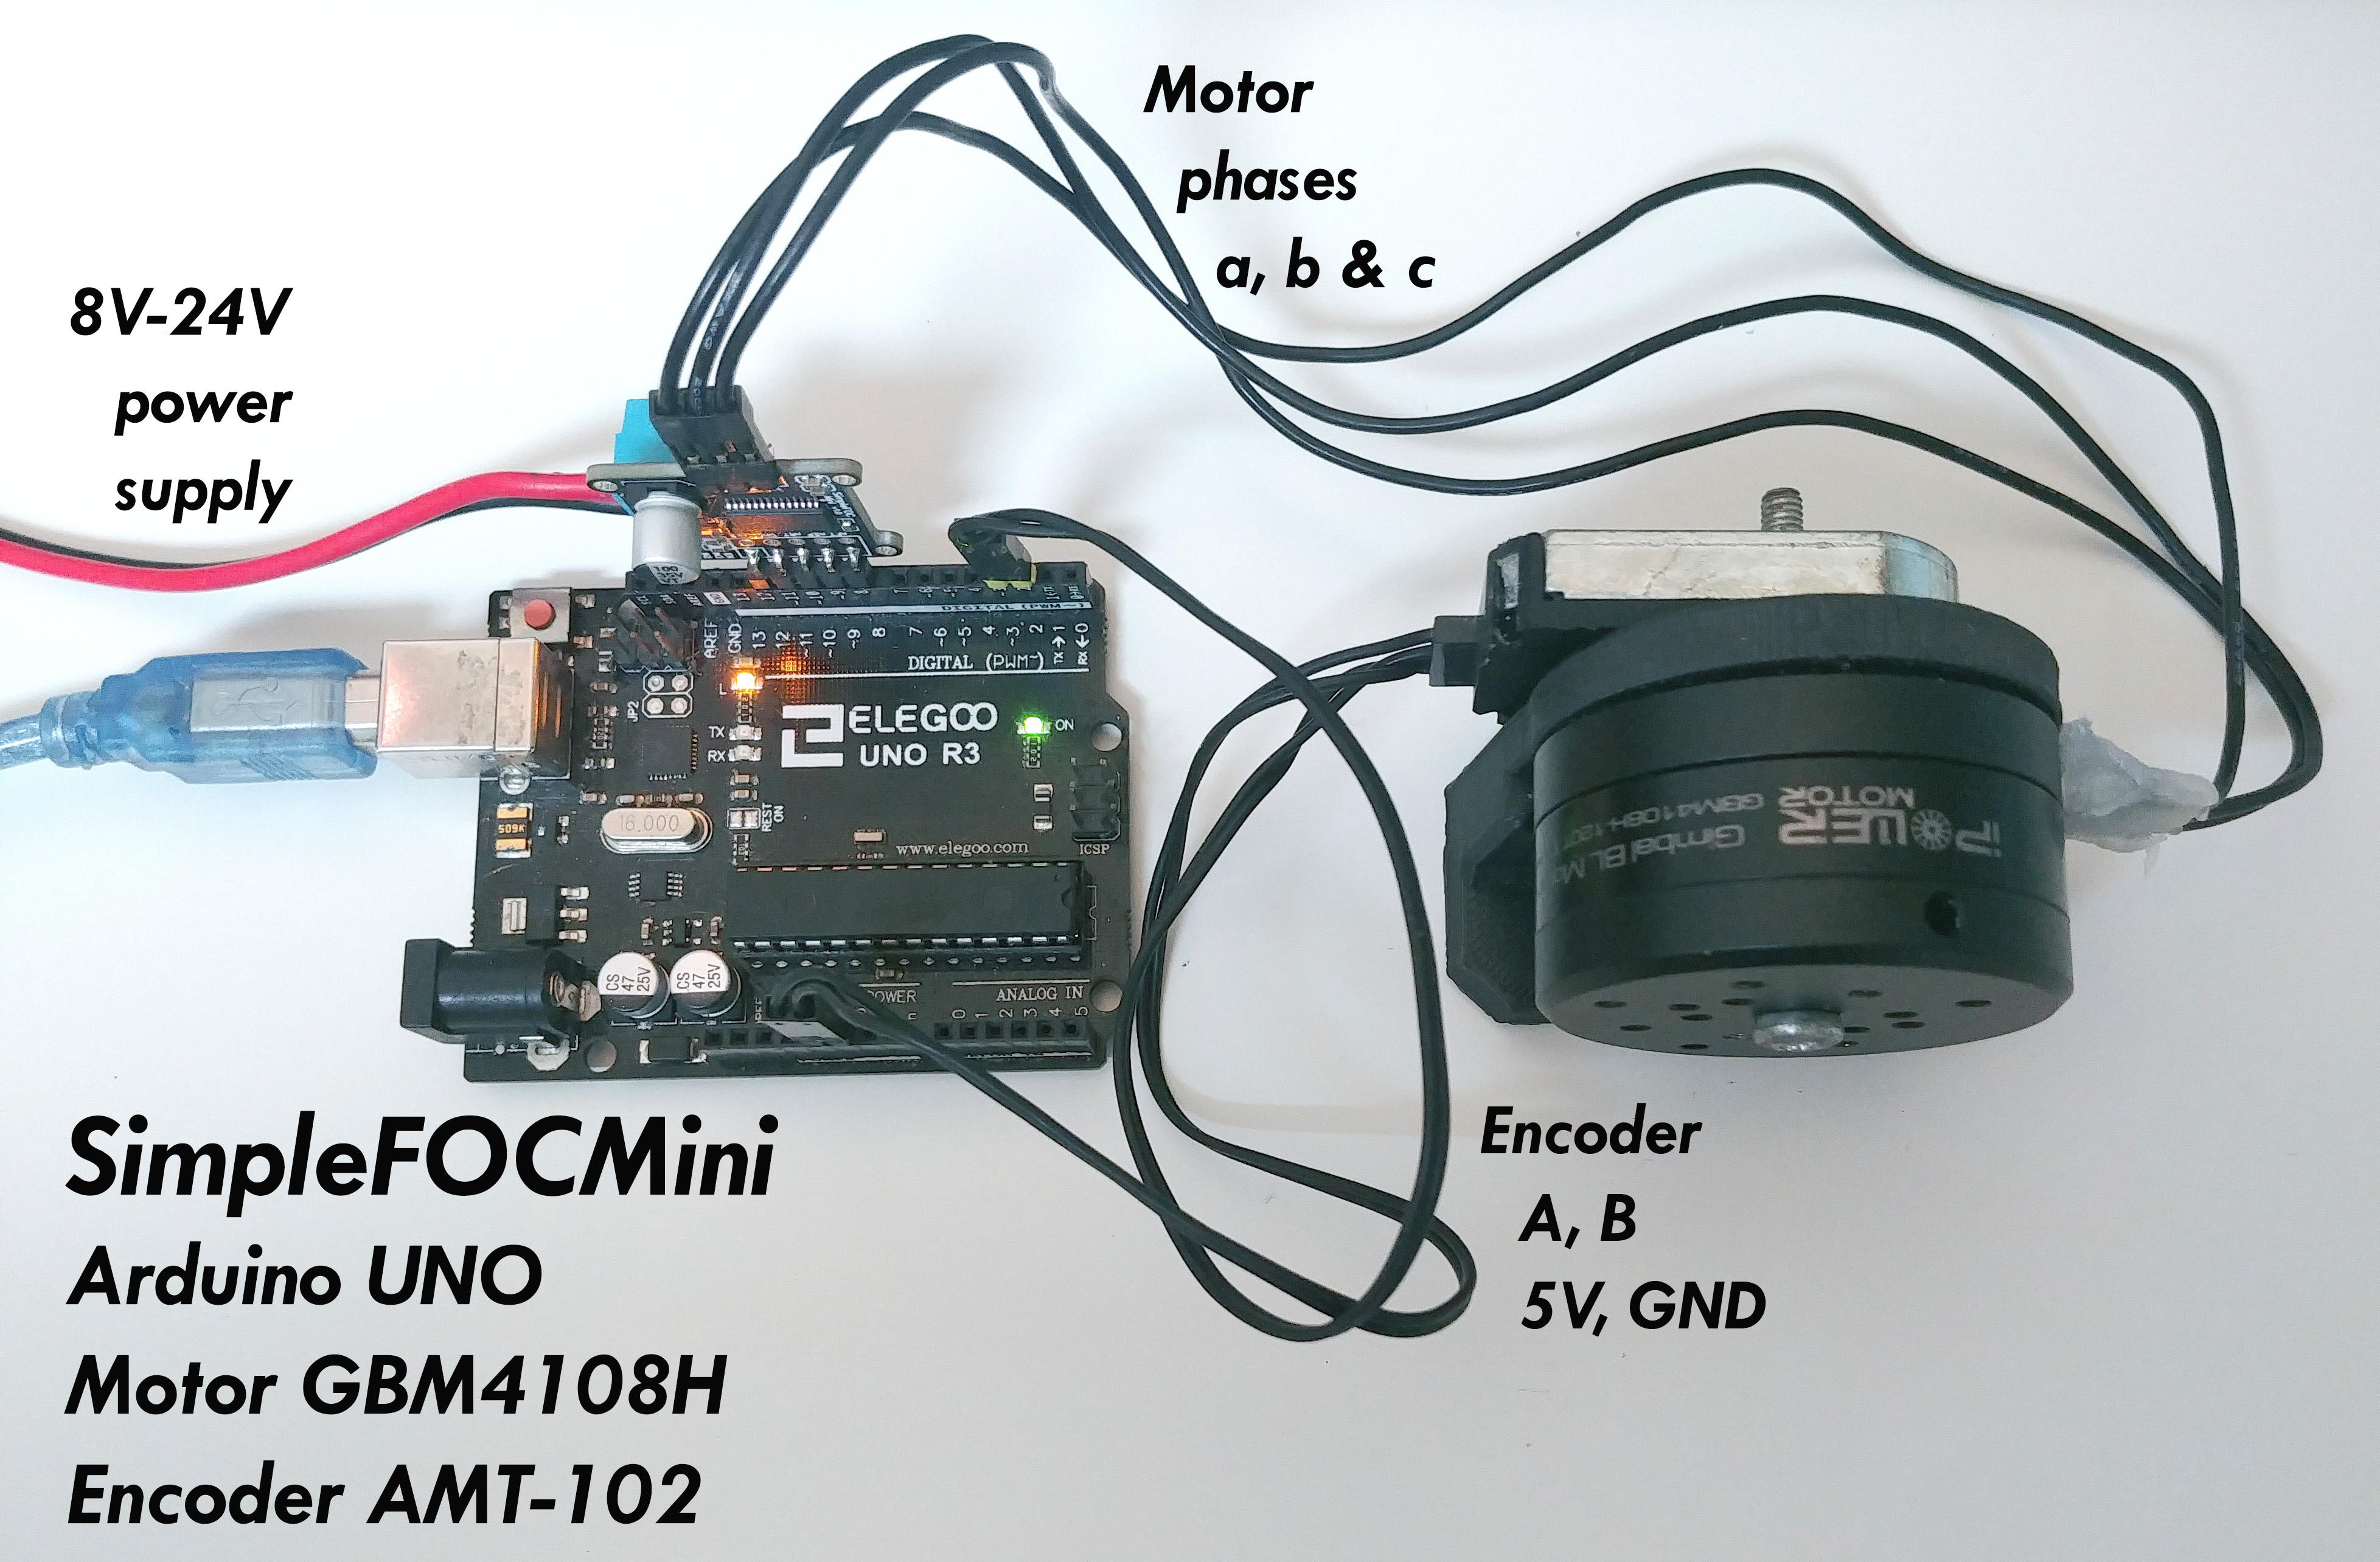
For the v1.1 pinout and a connection example, see connecting the Mini. The v2 board retains the v1.1 PWM and enable pinout.
Project example : Reaction wheel inverted pendulum
This is a project of designing and controlling the reaction wheel inverted pendulum based entirely on Arduino SimpleFOClibrary and SimpleFOCShield
This is a very fun project in many ways, and it is intended:
- Students in search for a good testing platform for their advanced algorithms
- Everyone with a bit of free time and a motivation to create something cool :D
For full documentation of necessary components, design choices and the code please visit the project docs.
📢 This project can be entirely done by using the SimpleFOCMini board.
Project example : Steer by wire - bidirectional haptic control examples
This video demonstrates SimpleFOCShield support for stacking with Arudino UNO and STM32 Nucleo-64 board. As well as support for different sensors magnetic and encoders with relatively large precision span.
The control algorithms implemented in this project are :
- Steer by wire (force feedback): two motors with virtually coupled positions
- Interactive gauge (haptic velocity control): two motors with virtually coupled position and velocity
For full documentation of the projects setup and the code please visit the project docs.
📢 This project can be entirely done by using the SimpleFOCMini board.
Getting started
You already have your own SimpleFOCMini?
How to get hold of the SimpleFOCMini
- Fabricate the board yourself: Board fabrication docs
- Order the finished and tested board: Check out our shop.